
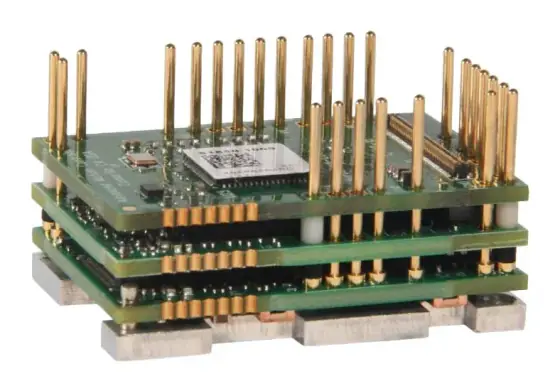
In short:Start from the environment the drive will actually see, not the one on a standard datasheet: temperature range and thermal shock, shock and vibration profile, altitude, humidity and salt, ingress and cleaning, supply transients and EMC. Then choose an extended-environment drive whose published ratings cover that profile with margin, and agree with the supplier which tests are evidence at component level and which must be done on your finished system.
A rugged servo drive is still a servo drive: the same power stage, current loop and feedback interface as an industrial unit. What makes it fit for a vehicle, an aircraft pod, a subsea vehicle or a hosed-down food line is the evidence that it keeps working across a wider envelope of temperature, shock, vibration, pressure, moisture and electrical noise. This guide walks through each stress in the order an applications engineer checks them, and explains what the military and aerospace standards do and do not prove at component level. For the basic sizing steps, start with how to select a servo drive.
Define the environment before choosing the drive
Write down the life-cycle environment first: storage, transport, operation and maintenance. Two mistakes are common. One is quoting the outside air temperature when the drive sits in a sealed box in the sun next to a motor. The other is quoting a standard (“MIL-STD-810”) without the methods, levels and durations the platform actually demands.
| Stress | What to state | Typical evidence from a drive maker |
|---|---|---|
| Temperature | Min and max ambient at the drive, storage range, solar load | Operating range, derating curve, thermal shock rating |
| Shock and vibration | Profile (sine, random, g rms, duration, axes), shock pulses | Test report to a stated method and level |
| Altitude / pressure | Maximum operating and transport altitude, depth if submerged | Altitude rating; derating; pressure test |
| Humidity, salt, fluids | Condensation, salt fog, fuels, cleaning chemicals | Humidity rating, conformal coating, materials list |
| Ingress | Dust, jets, immersion, washdown | IP code to IEC 60529 (and IP69K where relevant) |
| Supply | Nominal, min and max voltage; spikes, surges, reverse polarity | Input range, transient tolerance, design-to statements |
| EMC | Emission and susceptibility limits on the platform | Test data or design guidance; system test needed |
Wide-temperature servo drives
Standard panel drives are rated for a cabinet. An extended-environment drive is designed and screened for a wider band. ADVANCED Motion Controls publishes -40 to +95 °C ambient for its extended-environment FlexPro drives, with thermal shock across that whole range within three minutes and 0–95% non-condensing humidity (AMC flyer).
Points to check:
- Derating at the hot end. The headline continuous current is usually at a reference temperature. Read the current against ambient (or baseplate) curve at your hottest condition.
- Cold start. Ask whether the drive is specified to start, not only operate, at the minimum temperature, and how cold affects electrolytic capacitors and connectors.
- Thermal path. In a sealed enclosure the drive must reject heat by conduction into the structure. Model it: ΔT = P(loss) × Rθ, with Rθ from baseplate to outside air.
- Thermal cycling. Repeated swings fatigue solder joints and potting. Ask what cycling the design has been tested to.
Shock and vibration
Vibration damage usually shows up at connectors, heavy components and board mounting points. Published figures are only comparable when the profile is stated. AMC’s extended-environment FlexPro drives, for example, are published at 25 g rms for 5 minutes in each of three axes (A3). That is a useful indicator, but you still need to compare the frequency range and duration with your platform’s profile.
Design rules that help:
- Use locking or soldered connections, not friction-fit headers, and strain-relieve every cable.
- Mount the drive to a stiff structure and keep its natural frequency away from the platform’s dominant inputs.
- Choose robust feedback. AMC notes that some military users prefer resolvers because they measure position by inductive coupling, with no glass disc or sensitive electronics in the motor (AMC). See magnetic vs capacitive vs optical encoders.
Altitude and low pressure
Altitude affects drives in three ways:
- Cooling falls as air density drops. SEW-EURODRIVE applies no restriction below 1,000 m and reduces inverter line current by 1% per 100 m above that, up to 3,800 m (SEW-EURODRIVE).
- Insulation and clearances are rated for an altitude. SEW’s inverters meet overvoltage category III to EN 61800-5-1 up to 2,000 m, and need upstream overvoltage protection to reduce this to category II between 2,000 m and 3,800 m. Check the equivalent statement for any mains drive.
- Components can fail at very low pressure. AMC warns that high-altitude pressures can cause electrolyte evaporation that damages circuitry (AMC). Its extended-environment FlexPro drives are published for -400 m to +25,000 m operating altitude (AMC flyer).
For submerged vehicles the problem reverses: the drive normally sits in a pressure housing or an oil-filled, pressure-compensated enclosure. See waterproof and subsea slip rings and our subsea ROV and AUV page.
Humidity, salt and conformal coating
Condensation and salt bridge tracks on a bare board long before water reaches a connector. AMC offers conformal coating so that its PCB-mount drives can survive at sea or in high humidity (AMC). Specify:
- Coating on all boards, with connector areas masked as the maker specifies.
- Breathing and drainage: a sealed box that cycles in temperature pumps in moist air. Use a membrane vent or a desiccant, and avoid traps where water collects.
- Materials compatible with fuels, hydraulic fluid or cleaning chemicals present.
IP67 and washdown servo drives
Most drives are IP20 and rely on a cabinet. If the drive must sit in the wet or dusty zone, specify the IP code you need to IEC 60529 (Control Engineering):
| Code | Water protection |
|---|---|
| IP65 | Low-pressure jets from all directions |
| IP66 | Direct sprays from all directions |
| IP67 | Temporary immersion from 15 cm to 1 m for 30 minutes without ingress |
| IP68 | Continuous submersion under conditions set by the maker |
| IP69K | High-pressure, high-temperature spray (DIN 40050-9) |
IP67 is not a washdown rating. Food and pharmaceutical lines cleaned with hot, high-pressure water need IP69K and hygienic design, which is rare for drives; the usual answer is a sealed integrated or decentralised drive in the splash zone and the rest in a cabinet. See hygienic washdown actuators and IP69K and servo drive form factors explained.
MIL-STD-810, MIL-STD-461 and DO-160 at component level
These standards describe test methods. They are applied, with tailored levels, to the equipment a programme buys. A servo drive maker can supply data from testing to selected methods, or a statement that the design accommodates a standard. Treat both as evidence for your own qualification, not a substitute for it.
MIL-STD-810H (environmental engineering). The current revision lists methods including 500.6 low pressure (altitude), 501.7 high temperature, 502.7 low temperature, 503.7 temperature shock, 507.6 humidity, 509.7 salt fog, 510.7 sand and dust, 512.6 immersion, 514.8 vibration and 516.8 shock (DSIAC). Ask which methods, procedures and levels a drive was tested to, and get the report.
MIL-STD-461 (EMC). It covers conducted emissions (CE101, CE102), radiated emissions (RE101, RE102), conducted susceptibility (CS101, CS114, CS115, CS116) and radiated susceptibility (RS101, RS103) (Missouri S&T EMC Lab). A PWM drive is a strong conducted emitter, so the result depends on your filtering, cable screening and grounding. Plan system-level testing.
Power quality. AMC’s extended-environment FlexPro drives are designed to accommodate MIL-STD-1275D (military vehicle 28 V supplies), MIL-STD-704F (aircraft power), MIL-STD-461E and MIL-STD-810F, among others (AMC flyer). Note the revisions: a programme may specify a later one.
RTCA DO-160 (airborne equipment). Revision G (2010), equivalent to EUROCAE ED-14, has sections for temperature and altitude, temperature variation, humidity, shock and crash safety, vibration, power input, voltage spike, RF emission and susceptibility, lightning, ESD and more (Wikipedia). A component drive does not carry a DO-160 qualification for your aircraft; the line-replaceable unit it goes into is tested to the categories your installation requires.
Export control. Some rugged drives and assemblies for military end use fall under UK or EU dual-use or military control lists. The manufacturer and the buyer handle classification and licensing; flag the end use early.
Mobile and battery-powered drives
Vehicles, robots and portable equipment add supply problems that a mains drive never sees:
- Voltage range. Specify the battery’s full range from charged to cut-off, plus transients. A 24 V or 28 V vehicle bus needs margin for surges and dips.
- Regeneration into the battery. Braking pushes energy back onto the bus. If the battery management system is full or disconnects, the bus voltage rises. Fit a shunt regulator or confirm the battery accepts charge.
- Reverse polarity and load dump protection in the supply path.
- Low quiescent current and a safe way to remove power for long storage.
AMC’s AxCent and DigiFlex Performance ranges include vehicle-mount drives, the latter with an IP65 DV version for 20–80 V DC. See our AGV and AMR and drones and UAVs pages.
Worked example: a sensor mast pan axis on a 28 V vehicle
Requirement: the pan axis of a vehicle-mounted camera mast. Brushless motor with Kt = 0.08 Nm/A through a 50:1 gear, worst-case motor torque 1.2 Nm during slews and 0.3 Nm continuous against wind and friction. Vehicle supply nominal 28 V DC. Drive inside a sealed aluminium box on the mast, outside air -32 to +49 °C with solar load. Vibration and shock levels from the vehicle’s tailored MIL-STD-810H profile. EMC to the platform’s MIL-STD-461 tailoring.
Current:
- Peak: 1.2 ÷ 0.08 = 15 A
- Continuous: 0.3 ÷ 0.08 = 3.75 A, call it 4 A rms over the cycle
Temperature inside the box: assume solar load and the drive’s own losses lift the box interior 25 °C above the 49 °C air, so the drive sees about 74 °C. At 28 V and 4 A, output power is around 100 W; at an assumed 97% efficiency, loss is about 3 W, so the drive itself adds little. The hot ambient dominates.
Candidate check: an extended-environment FlexPro rated 10 A continuous and 20 A peak at 10–55 V DC covers 4 A rms and 15 A peak with margin, and its -40 to +95 °C rating covers 74 °C. Confirm the continuous rating at 74 °C on the derating curve.
Supply: 28 V sits well inside 10–55 V, but the supply path still needs transient suppression and reverse-polarity protection for the vehicle’s tailored MIL-STD-1275 conditions, and bus capacitance close to the drive. Slew deceleration regenerates only a few joules, but add a shunt or clamp in case the vehicle bus cannot accept it.
Evidence package: the drive maker’s vibration and thermal data, plus your own system-level shock, vibration and MIL-STD-461 tests on the complete mast electronics with production cables.
Checklist
Send these to our engineers, or enter them in the spec builder:
- Operating and storage temperature at the drive, solar load, thermal shock rate
- Vibration and shock profiles (method, levels, duration, axes), not just a standard number
- Maximum altitude or depth, and pressure at transport
- Humidity, condensation, salt fog, fluids and cleaning chemicals
- IP code needed, and whether the drive can sit in a cabinet outside the zone
- Supply: nominal, range, transients, battery chemistry and regen acceptance
- EMC requirement (MIL-STD-461 tailoring, DO-160 categories or EN 61800-3)
- Motor type, feedback (resolver or encoder), continuous and peak current
- Size, mass and cooling path available
- Evidence needed: test reports, design-to statements, conformal coating, materials
- End use for export classification
- Volumes and programme lifetime, including obsolescence management
Products in our range to consider
- ADVANCED Motion Controls FlexPro: 10–90 V DC, up to 100 A continuous, with extended-environment FX/FXE/FXM models for 10–55 V DC rated -40 to +95 °C and STO as standard.
- ADVANCED Motion Controls DigiFlex Performance: 10–747 V DC and 120–480 V AC, including DZX extended-environment PCB drives (-40 to +75 °C) and IP65 DV vehicle-mount drives up to 250 A peak.
- ADVANCED Motion Controls AxCent: analogue drives commanded by ±10 V or PWM, with AZX extended-environment PCB parts for -40 to +85 °C and vehicle-mount AV/AVB models.
- Novanta Everest servo drives: 8–72 V DC, 45 A continuous, 60 A peak, offered in high- and low-temperature versions for unmanned vehicles and robots.
- Novanta Capitan servo drives: 18 g micro drive for 8–60 V DC at 10 A continuous and 20 A peak, with STO SIL 3 and high- and low-temperature versions.
- Kinco iSMK integrated DC servo motors: drive built into the motor, 100–750 W on 24–60 V DC, IP65 as standard with IP67 optional.
Related pages
- Servo drive form factors explained and how servo drives work
- How to select a PCB-mount servo drive
- Defence and security, military drones and UAVs and armoured vehicle systems
- Our servo drives overview
Frequently asked questions
What temperature range can a rugged servo drive operate in?
Extended-environment drives are published for much wider ranges than industrial drives. ADVANCED Motion Controls rates its extended-environment FlexPro drives for -40 to +95 °C ambient and thermal shock across that range within three minutes. Standard panel drives are usually rated for a much narrower ambient band and derate above it, so always read the derating curve at your worst case.
Is a MIL-STD-810 servo drive qualified for my platform?
Not automatically. MIL-STD-810H is a set of test methods, such as 500.6 low pressure, 514.8 vibration and 516.8 shock, that are tailored to a platform's life-cycle environment. A drive maker can test to selected methods and levels, or design to accommodate them. Your programme decides the tailored levels and whether component evidence is accepted or the assembled system must be tested.
Does altitude affect a servo drive?
Yes, in two ways. Thinner air cools less, so drives derate: SEW-EURODRIVE, for example, reduces inverter current by 1% per 100 m above 1,000 m. Lower pressure also reduces the voltage that air gaps can withstand, so mains drives rated to EN 61800-5-1 for 2,000 m may need extra overvoltage protection above that. Low-voltage drives for aircraft are designed for much higher altitudes.
What does DO-160 mean for a servo drive?
RTCA DO-160 (EUROCAE ED-14) defines environmental and EMC test procedures for airborne equipment, in sections covering temperature and altitude, vibration, shock, humidity, power input, voltage spikes, RF emissions and susceptibility, lightning and more. For a drive bought as a component, DO-160 data is supporting evidence; the qualification is carried out on the equipment that is installed on the aircraft.
Do I need conformal coating on a servo drive?
Where humidity, condensation, salt or conductive dust can reach the electronics, yes. ADVANCED Motion Controls offers conformal coating so that even its PCB-mount drives can survive at sea or in high humidity. Coating does not make a drive waterproof; it protects the board surface. You still need an enclosure with a suitable IP rating and a plan for condensation.
What IP rating does a servo drive need for washdown?
It depends on the cleaning. IP65 covers low-pressure water jets and IP67 temporary immersion from 15 cm to 1 m for 30 minutes. High-pressure, high-temperature cleaning is covered by IP69K. Most servo drives are IP20 and live in a cabinet; for washdown areas, use a sealed decentralised or integrated drive, or put the drive in a cabinet outside the wet zone.
Sources
- ADVANCED Motion Controls: FlexPro Extended Environment product flyer
- A3 (automate.org): ADVANCED Motion Controls introduces Extended Environment machine-embedded FlexPro drives
- ADVANCED Motion Controls: Servo control for military and aerospace applications
- DSIAC: MIL-STD-810H test methods
- Missouri S&T EMC Laboratory: MIL-STD-461 test summary
- Wikipedia: DO-160
- SEW-EURODRIVE: Derating due to the installation altitude
- Control Engineering: Understanding proximity sensor IP ratings
Figures are summarised from the sources above and from manufacturers' published data on the date shown. Always confirm against the current datasheet for your exact part.